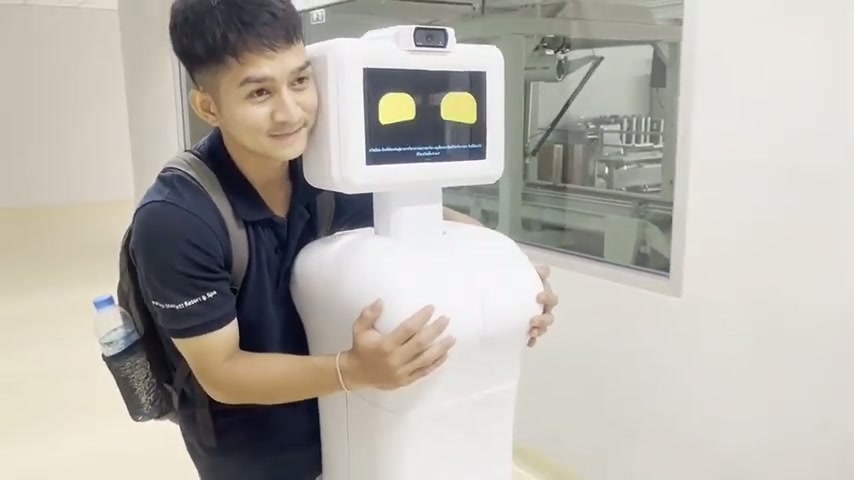
Thanakrit Wongkha
I build robots that see, move, and act.
I connect electrical systems, ROS2 autonomy, and AI into robots that people can actually operate.
✳ Chonburi, Thailand · LinkedIn ↗ · GitHub ↗
to field demo.
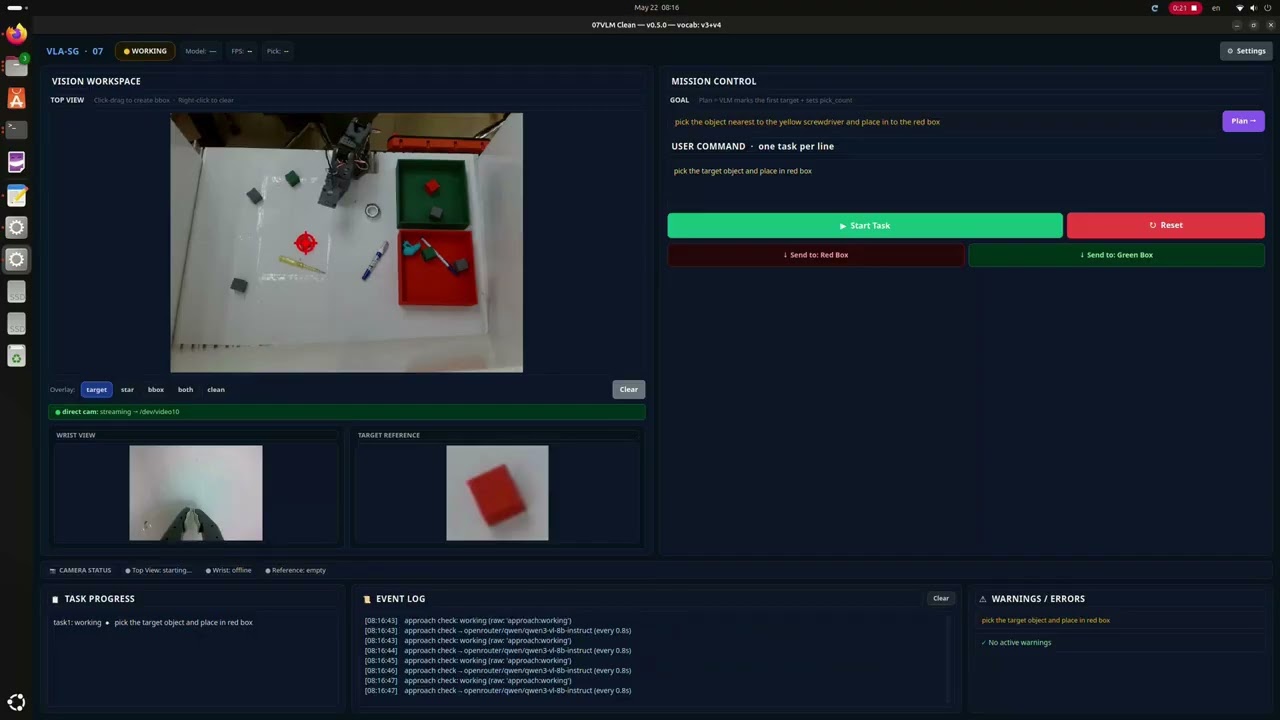
VLA ROBOTIC ARM · 2026
From a sentence to a robot action.
A language-conditioned pick-and-place system combining semantic grounding, live visual tracking, and a locally run robot policy.
A cloud VLM grounds the instruction to a target bounding box.
OpenCV tracks the target without a new VLM call on every frame.
Local SmolVLA predicts actions for the 6-DoF SO-101 arm.

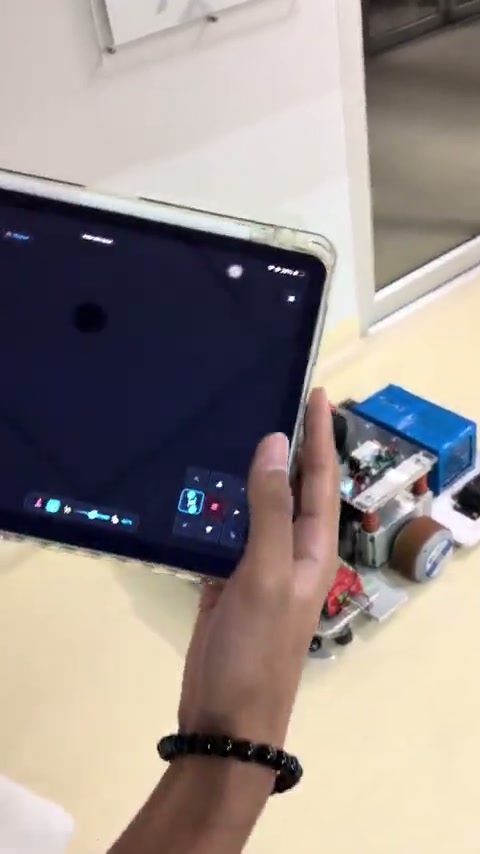
MARS RECEPTIONIST ROBOT · 2024–2026
A robot that welcomes and guides.
My team built the mechanical chassis; I made the original prototype navigate and work as a complete electrical and software system.
Built the original prototype’s complete software stack and electrical wiring.
Integrated ROS2 Nav2 with LiDAR, IMU, and Intel RealSense.
Returned as an AI contributor and technical advisor.
INDUSTRIAL AMR · 2025–2026
The control brain for 200 kg payloads.
During a four-month internship, I built the controls for a differential-drive R&D AMR designed to carry up to 200 kg.
Owned the electrical wiring and robot-control programming.
Built the web-based operator interface.
Designed its ROS2 / OpenRMF simulation and fleet architecture.
SUI · OPEN SOURCE · 2026
Agents that build.
A runtime in Rust.
An AI coding harness that turns a task into coordinated implementation, with the runtime owning checks and integration.
Isolated git worktrees keep each worker's changes separate.
A mouse-enabled Ratatui interface puts tasks and permissions in one terminal.
Auditing and acceptance gates decide which changes integrate.
Task → work contracts
Isolated git worktrees
Review → check → integrate
$ sui --mission
BEYOND THE ROBOT
I build the tools around the work.
The same approach carries into public software: identify a friction point, build the useful tool, and document it so others can use it.
Fn + click becomes a true middle click and drag on a trackpad, built for Blender, Maya, and CAD.
CGEventTap · drag-state handling · DMG release 02 / ROBOTICS OPEN SOURCEROS2 ↗ YDLIDAR for JazzyUpdated the ROS2 driver for Jazzy and S2PRO hardware, with configuration, RViz QoS fixes, and setup guidance.
C++ · sensor integration · 2 authored commits